Digital twins
Every greenhouse, aisle and selected plant has a living mirror. Interventions can be simulated before they touch tissue.
Technology
governed end to end.
NARI™ is MahaaAi’s top-level Nature-Aware Robotic Intelligence layer, connecting plant understanding, Digital Twins, reasoning, Somavati governance, robotics and traceable evidence. Somavati provides the governed safety, decision and orchestration subsystem within NARI.
NARI™ · MahaaAi Intelligence Grid™
NARI is MahaaAi’s top-level Nature-Aware Robotic Intelligence layer, connecting plant understanding, Digital Twins, reasoning, Somavati governance, robotics and traceable evidence.
Somavati is the governed safety, decision and orchestration subsystem inside NARI, providing policy checks, confidence bounds, fail-closed controls and human override.
01
Observe the physical environment through available field, robot and sensor inputs.
02
Convert observations into contextual environmental understanding.
03
Update the relevant Digital Twin representation of plant, environment, robot or mission state.
04
Evaluate context, relationships, evidence and potential actions.
05
Apply Somavati safety, policy, confidence and decision guardrails before physical action.
06
Execute approved actions through robotic and automation capabilities.
07
Capture outcomes and evidence to improve subsequent decisions under human oversight.
NARI™ intelligence
NARI is the temperament of the stack: prefer biological resilience over unnecessary synthetic inputs, plant-scale truth over field averages, and a safe state over an unexplained act.
Every greenhouse, aisle and selected plant has a living mirror. Interventions can be simulated before they touch tissue.
RAKSHA applies explicit constraints and fail-closed authorization before an autonomous physical action may proceed. Current evidence is a software-level Safety Gate in simulation; physical validation is planned.
Sense-to-learn is an audit trail, not a slogan. Growers, researchers and regulators can ask why a plant was watered, pruned, or left alone.
Character intelligences
DHARA™
Fuses soil, climate, phenology and crop signals into a living representation of plant need.
DRISHTI™
Combines RGB-D, multispectral and spatial perception to observe plants, fruit, aisles and operating environments.
JALA™
Connects plant demand, soil moisture, climate and irrigation outcomes to support precision water decisions.
KSHETRA™
Transforms plant and environmental understanding into bounded operational plans across robots, tasks, energy, water and time.
RAKSHA™
Applies safety constraints, policy checks and fail-closed behavior before autonomous physical actions are authorized. Operates with Somavati governance. Current evidence is a software-level Safety Gate in simulation; no functional-safety certification is claimed.
ANKUR™
Tracks plant development and verified outcomes to improve future decisions under governed learning and human oversight.
JALA™ · intelligent water
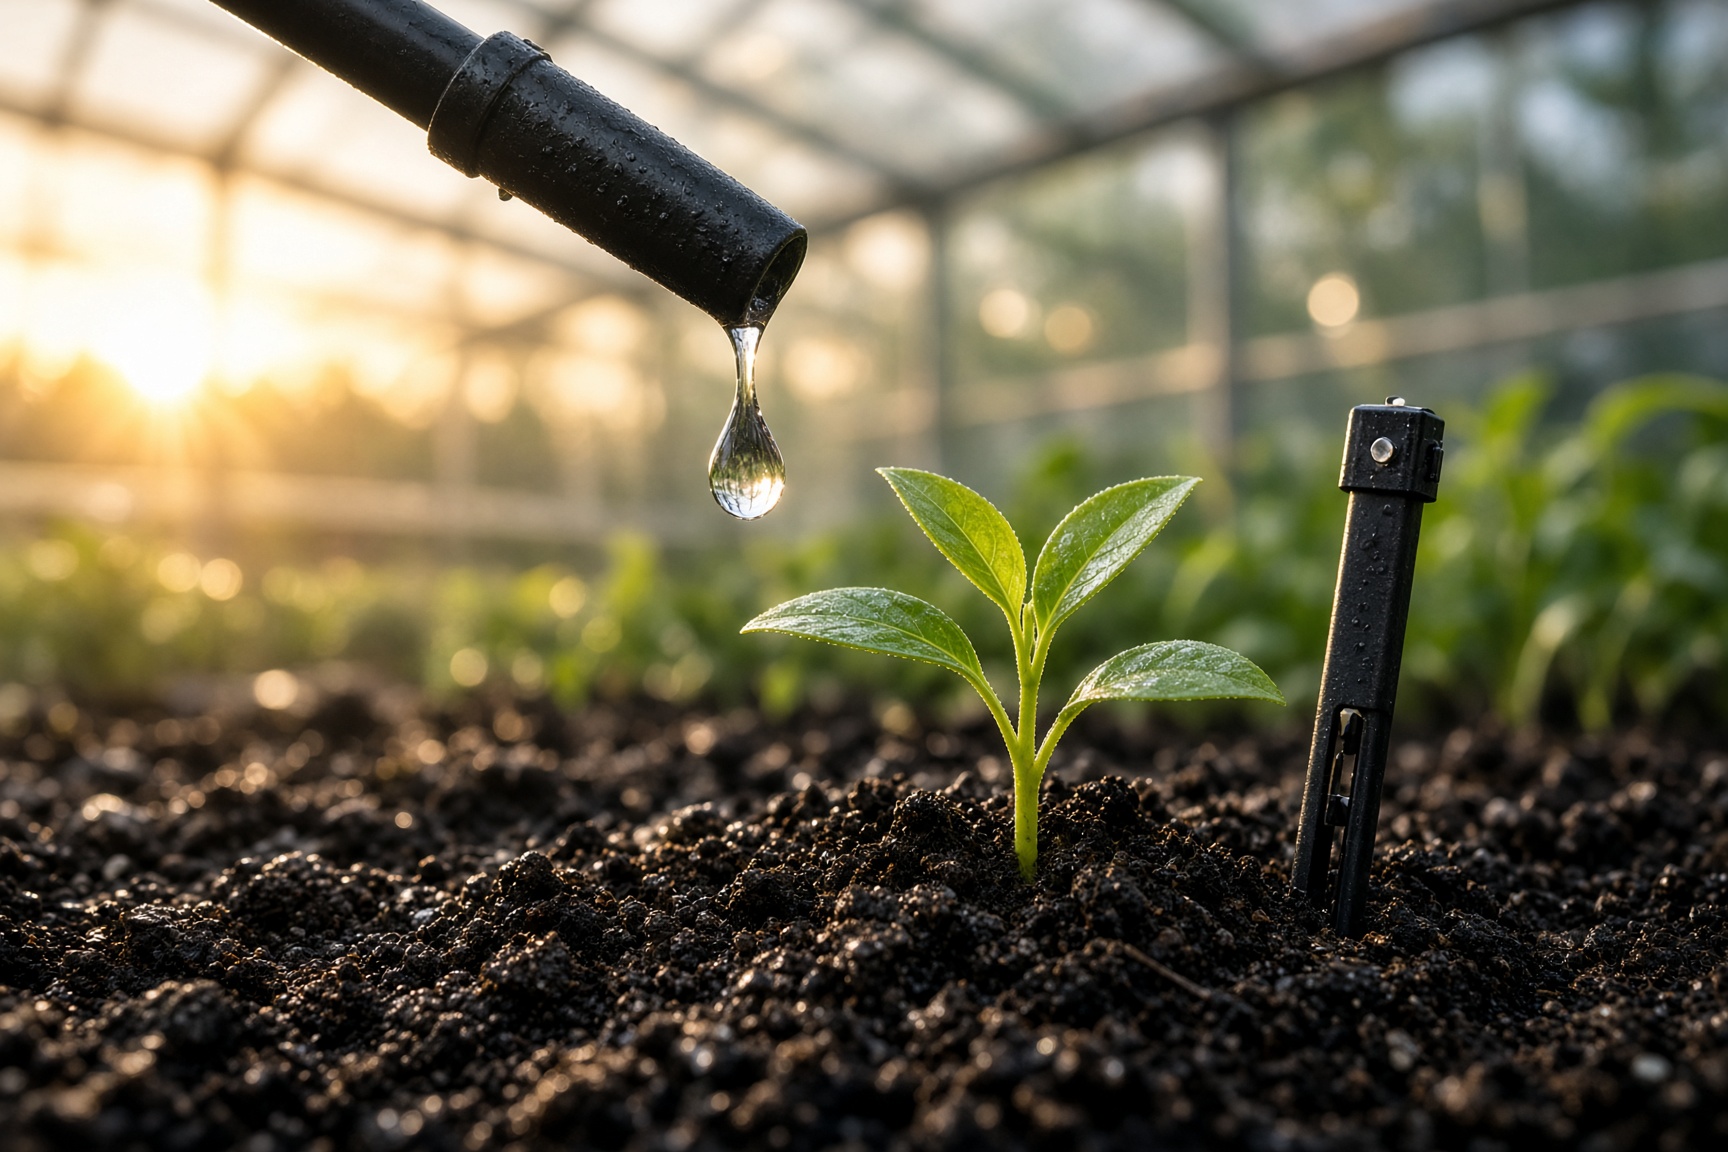
Soil moisture, transpiration, weather and reuse capacity compose a watering plan at plant scale. Rain is harvested, filtered, mineral-balanced and returned. Nothing in the loop is ornamental.
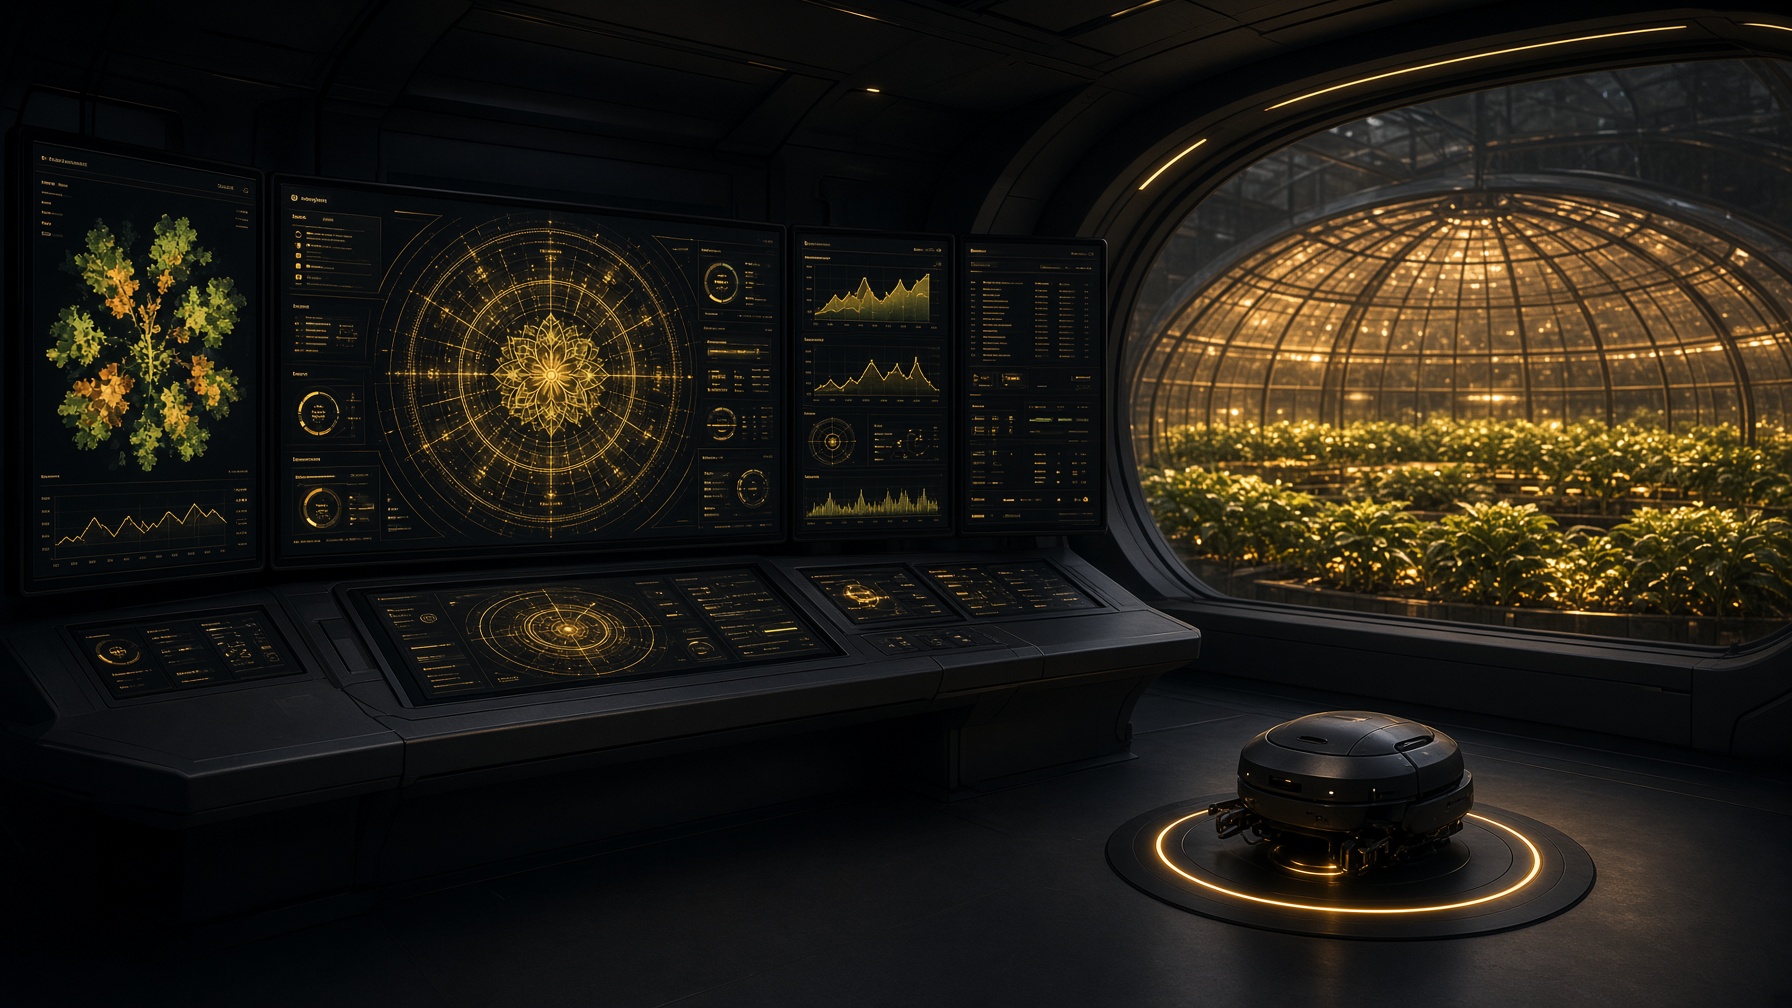
The interactive Control Tower is a labeled synthetic demonstration of a Control Tower operational view mapped to the 7-stage NARI Intelligence Lifecycle. Demonstration telemetry is generated from synthetic simulation unless explicitly labelled as physical-test data. It is read-only and does not control physical robots. It does not expose private GitHub files, source code, credentials, physical actuator controls or live production telemetry.